Engineering Portfolio
Meredith
Scharlach
Mechatronics and Robotics Engineering student interested in field robotics, control systems, and applied research.
A collection of engineering projects, research work, design builds, and technical experiments. Including a short description of each project, the skills used, and the tools and technologies applied.
Projects
MATLAB Simulink Controls
Autonomous Sailboat Controller
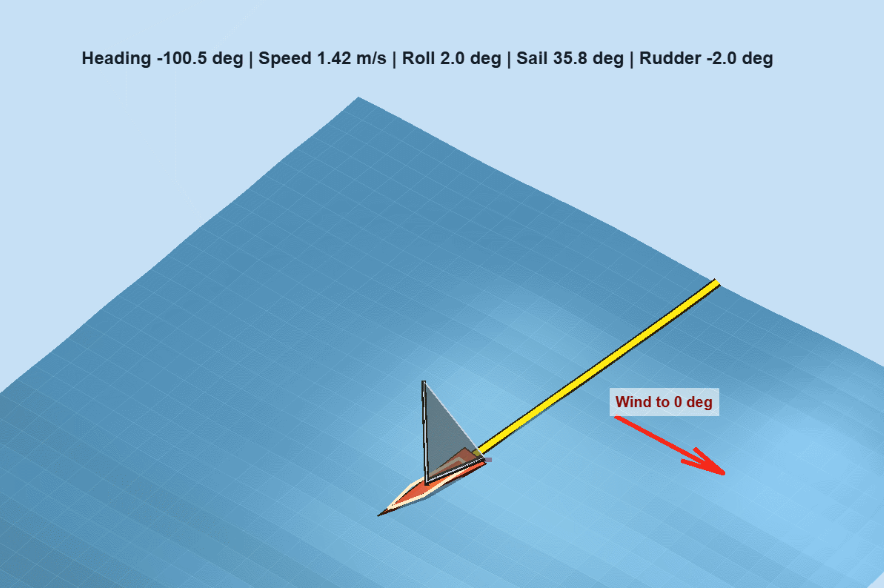
Developed and tested control strategies for an autonomous sailing platform using a simulated yacht model. The project involved tuning parameters, analyzing boat motion, and improving heading control behaviour.
- Worked with MATLAB and Simulink simulation models
- Adjusted controller gains and boat parameters
- Created custom visualization tools for simulation results
ROS 2 Arduino Raspberry Pi
Mars Sample Retrieval Rover
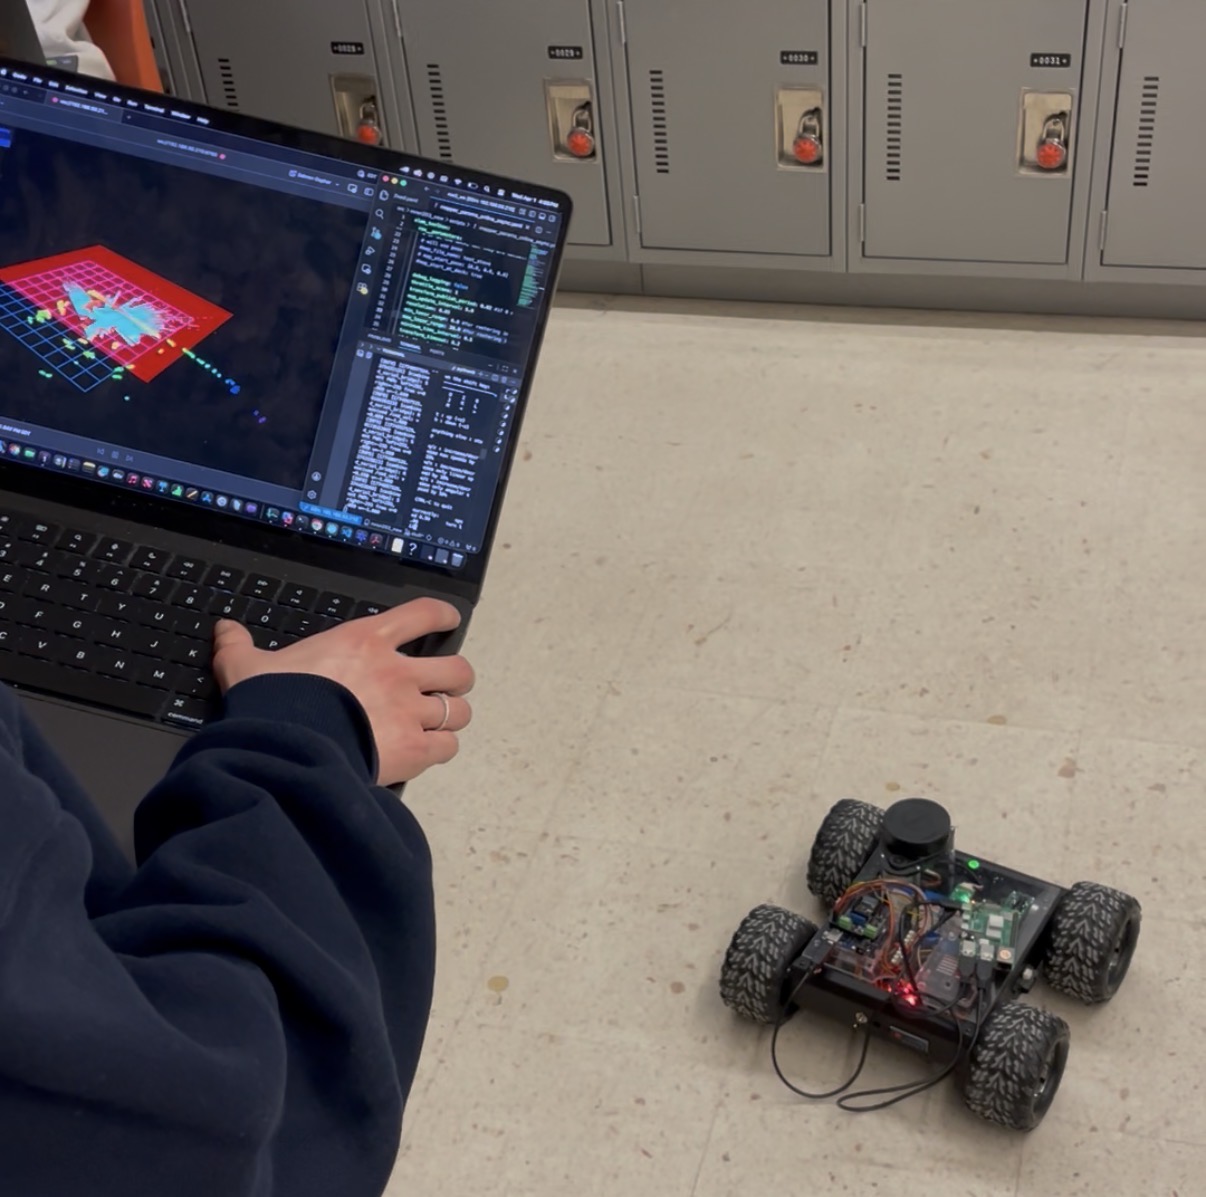
Designed a conceptual rover system for retrieving sample tubes on Mars and transporting them to a lander. The project included mechanical design, navigation planning, system requirements, and prototype development.
- Integrated Arduino motor control with ROS 2
- Used encoder and IMU feedback for movement testing
- Worked with LiDAR data and mapping tools
- Created system requirements and design constraints
- Designed rover intake and storage concepts
- Considered navigation, thermal, and planetary constraints
ROS 2 Hardware Field Robotics
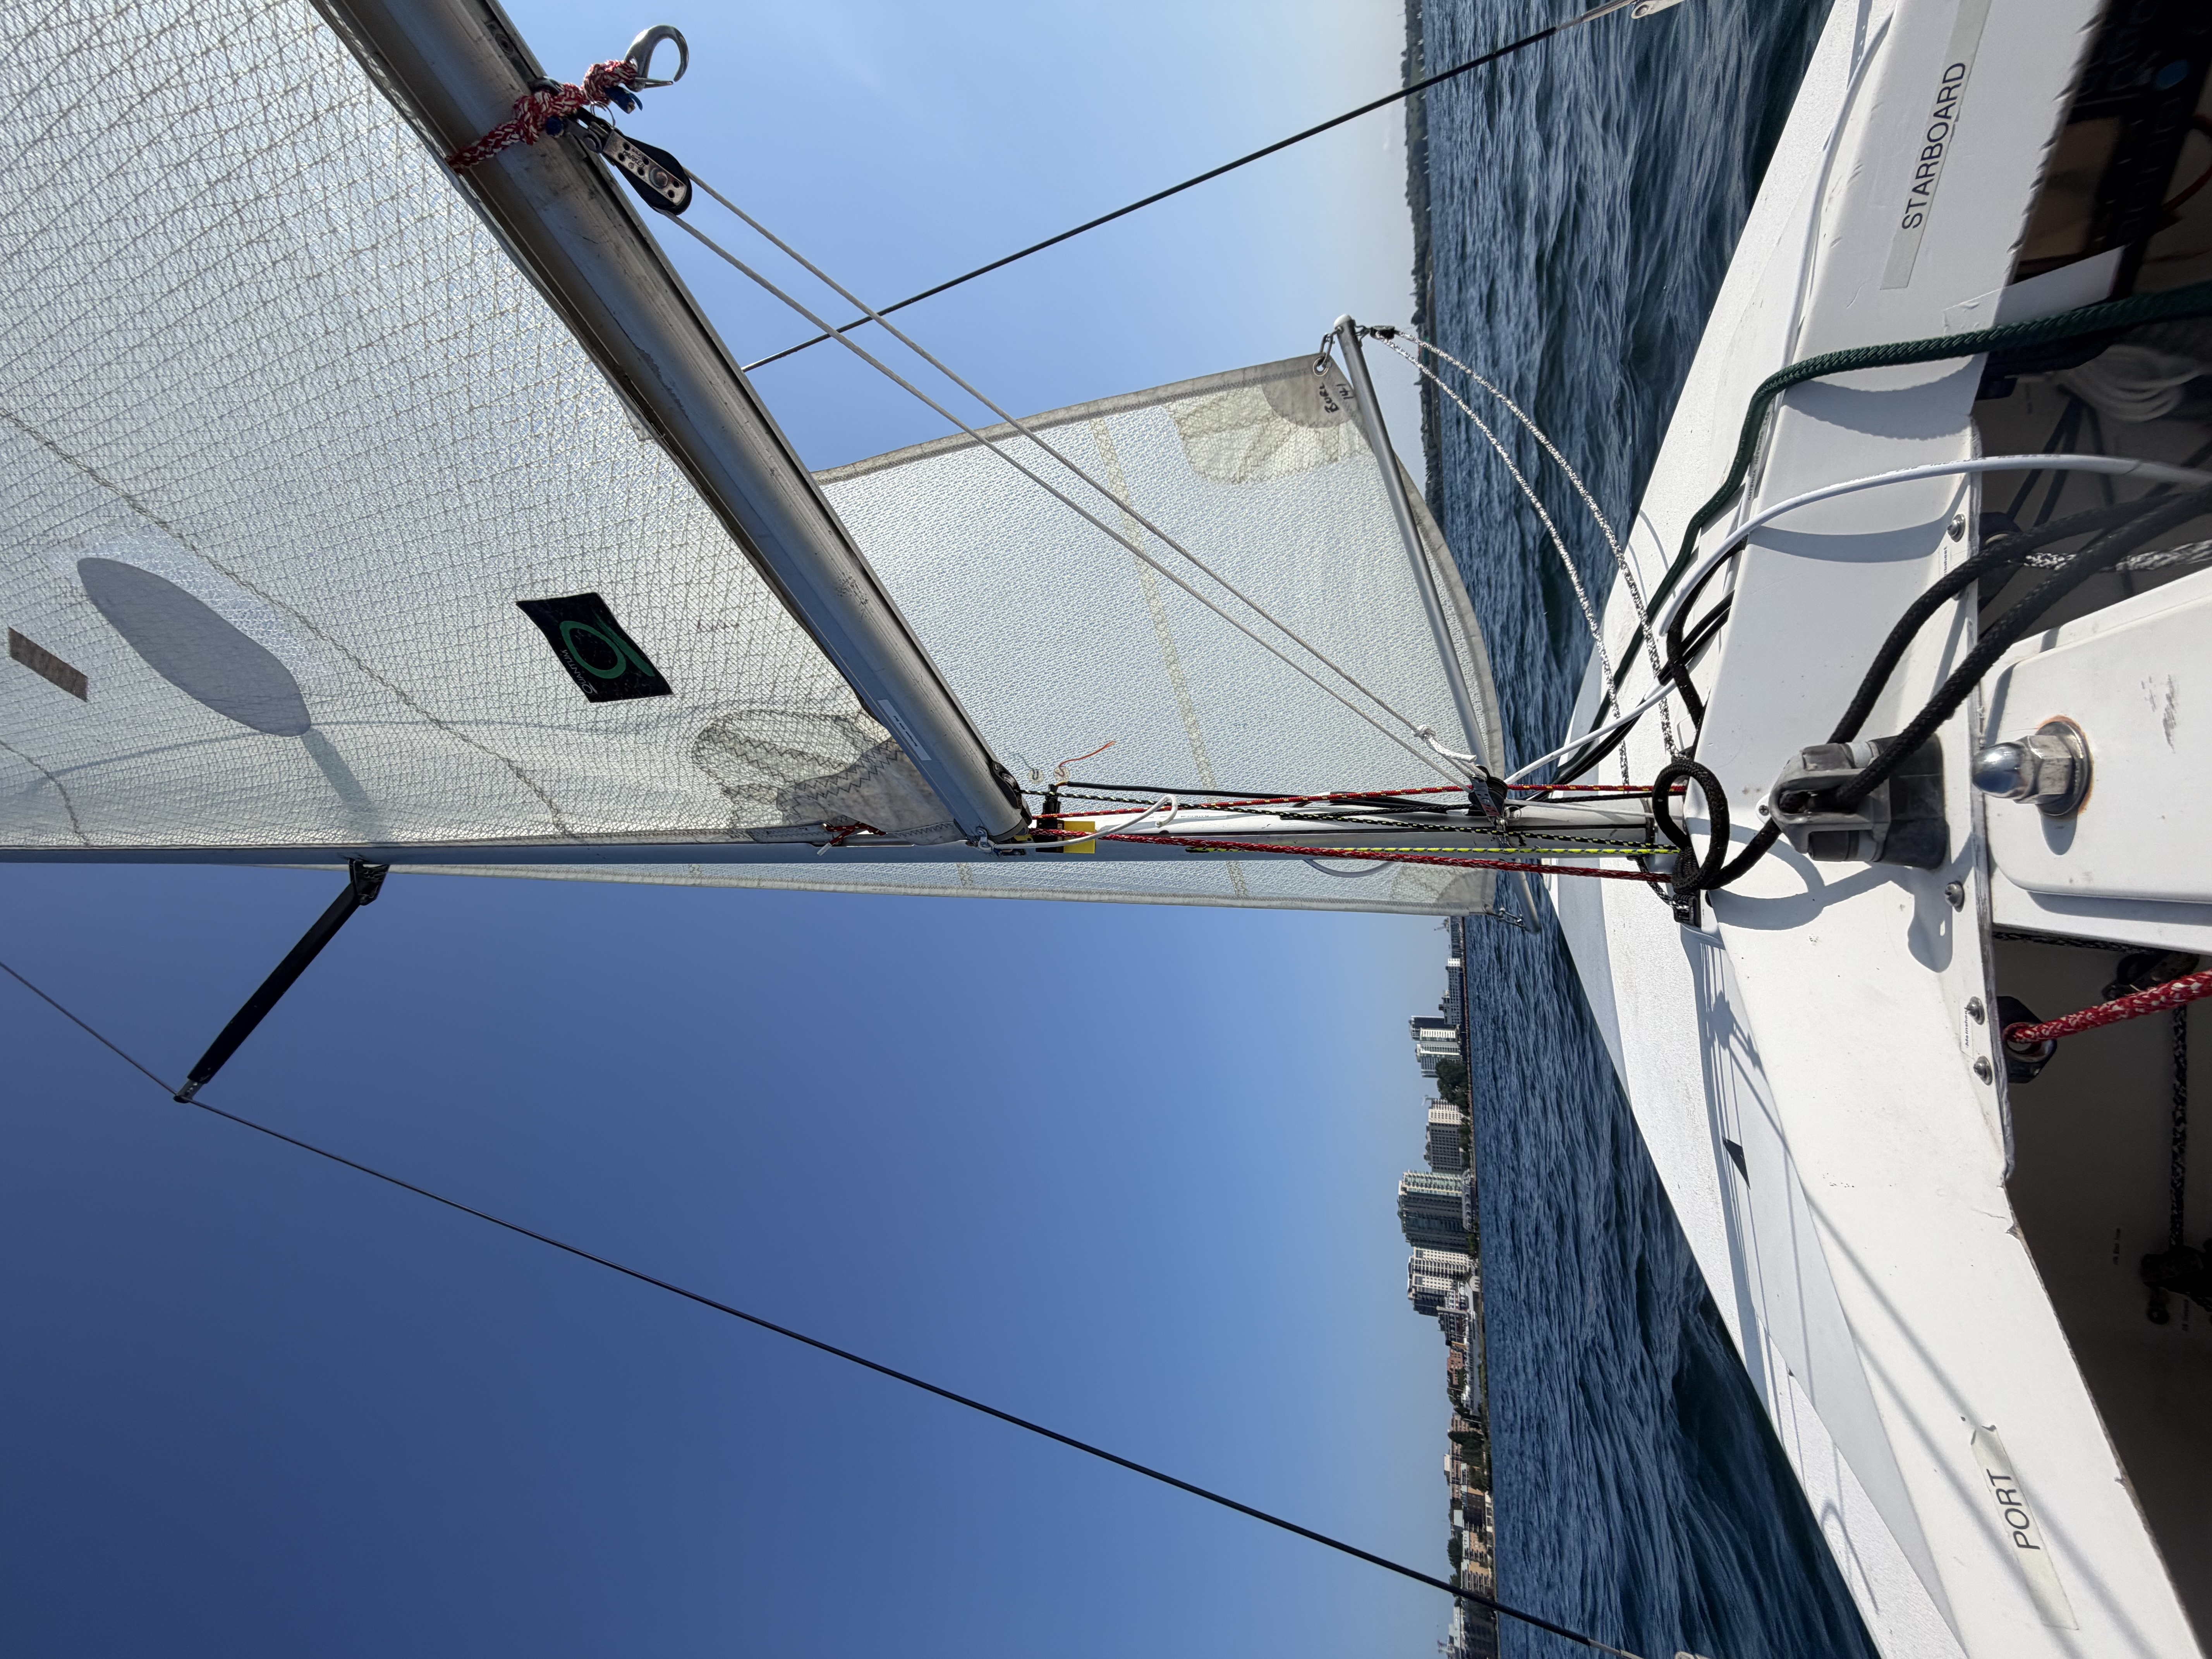
Martin 16 Adapted Autonomous Sailboat
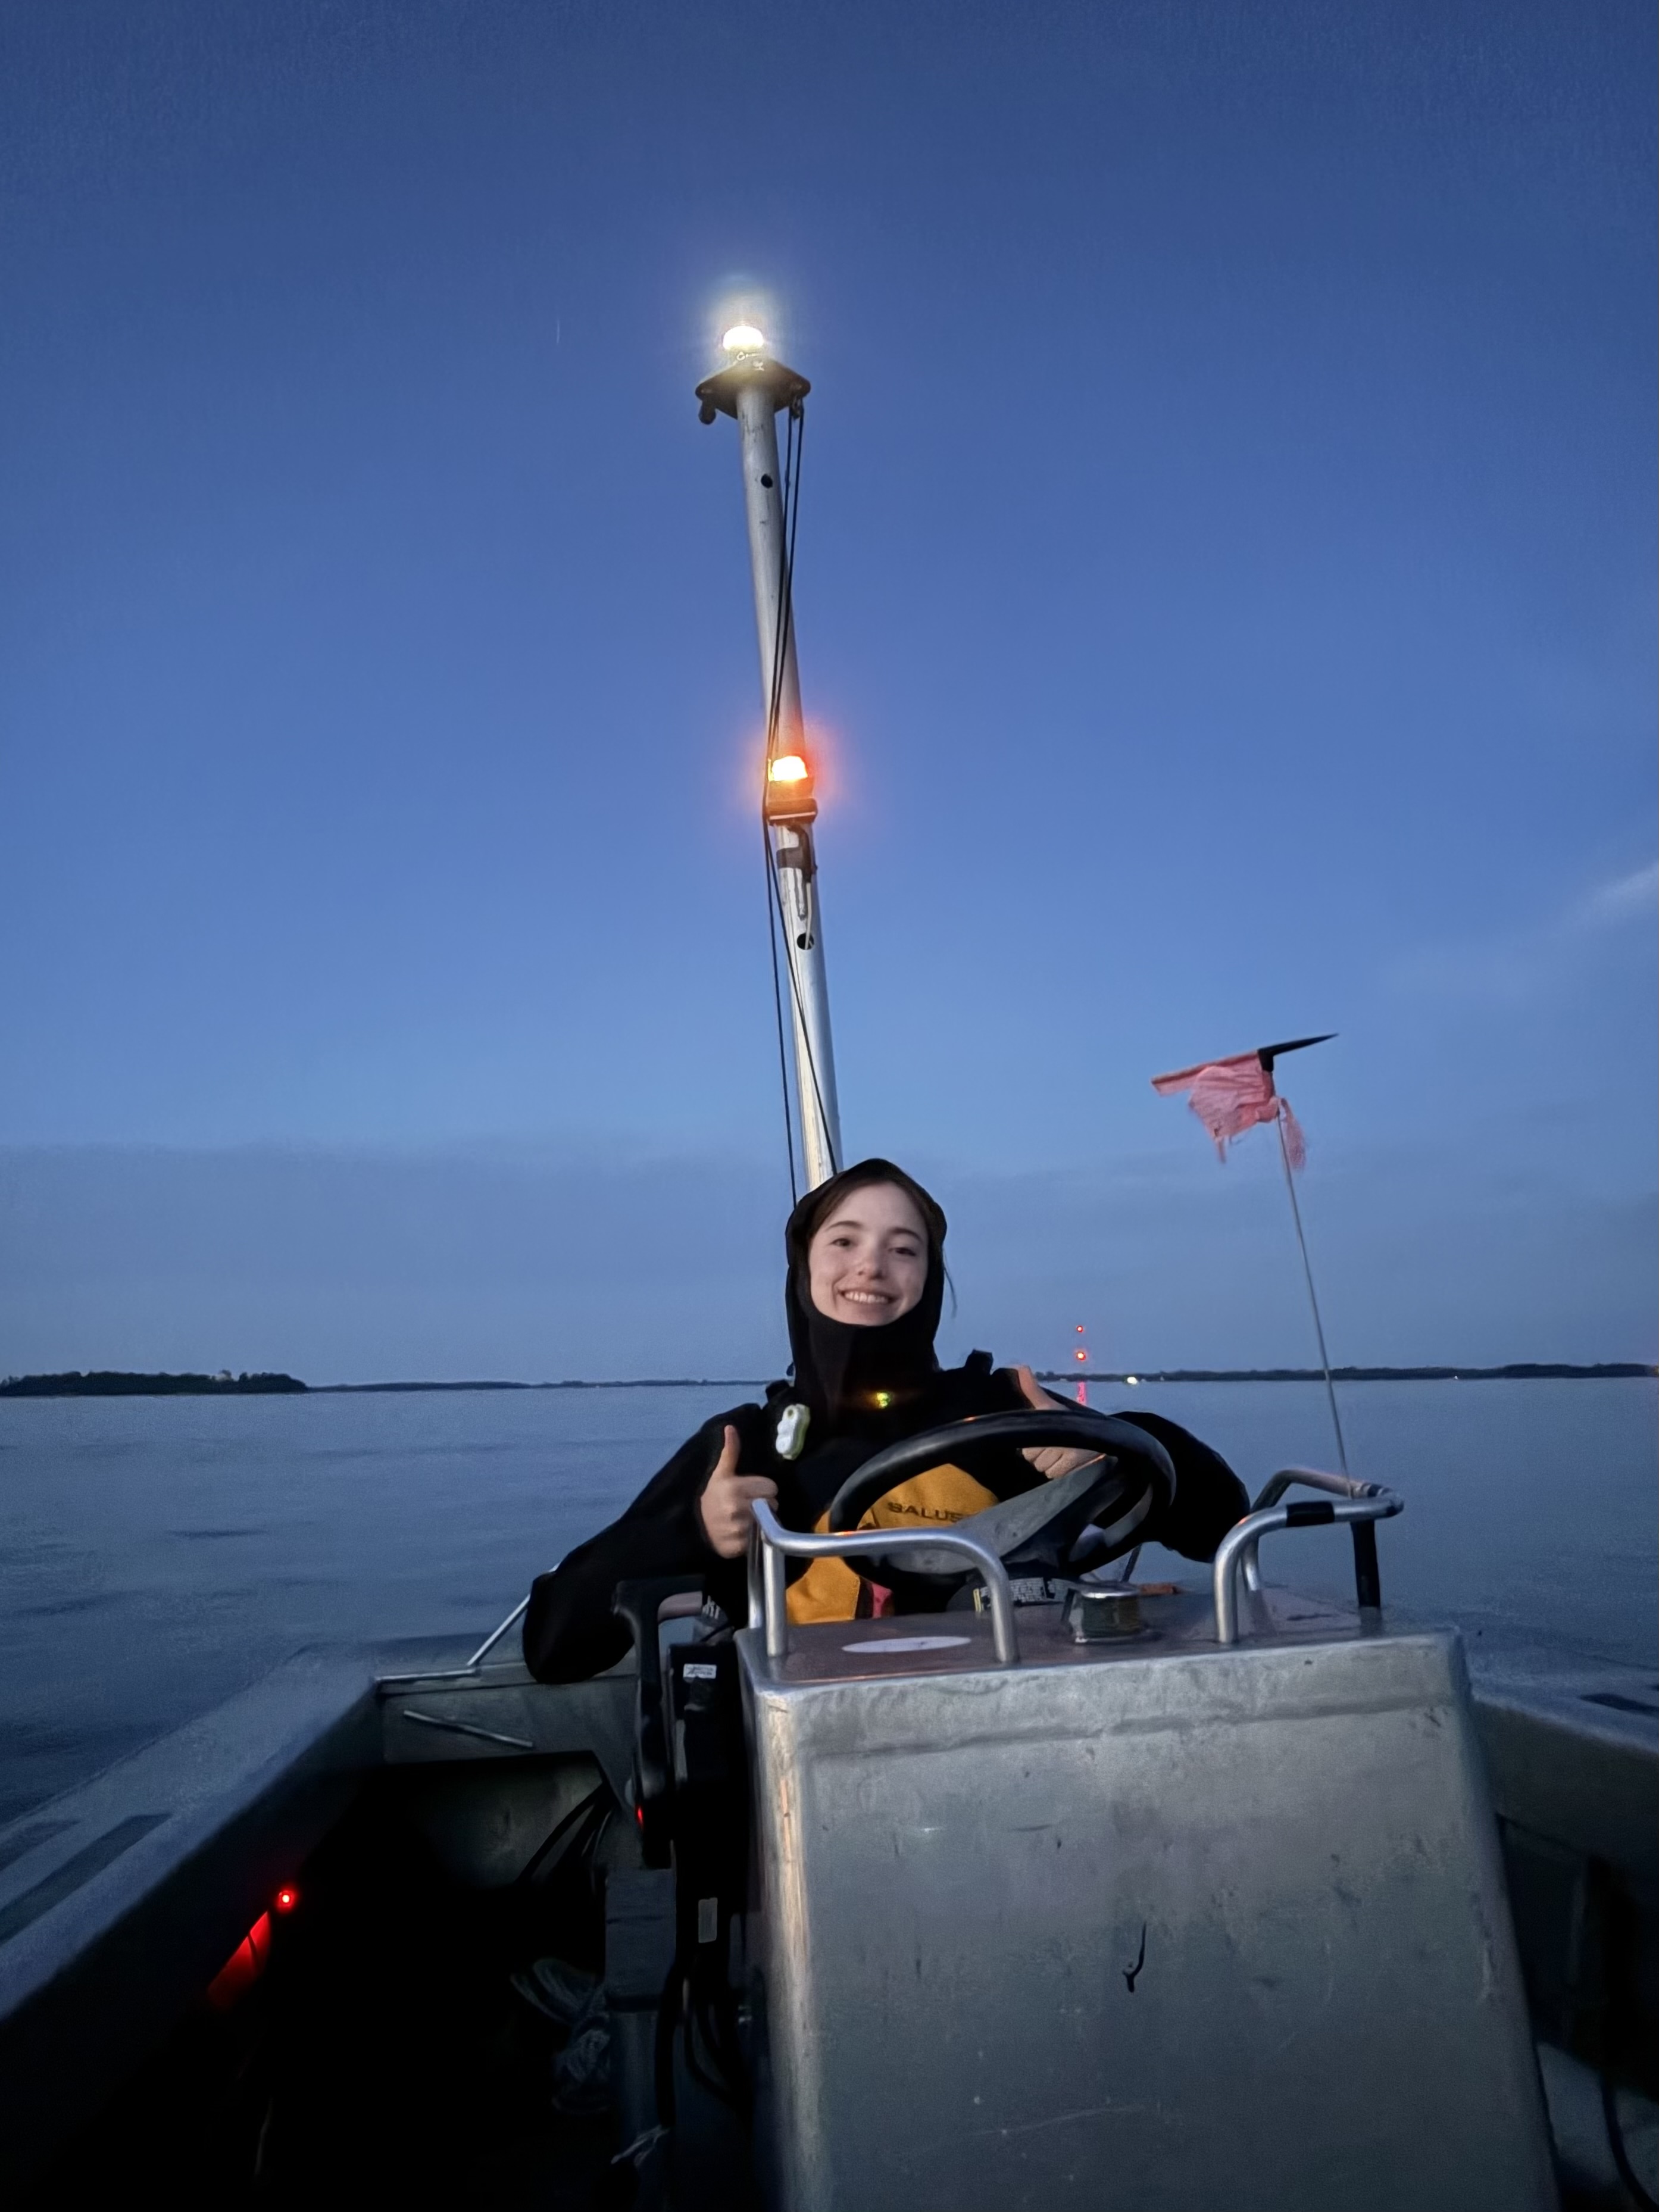
Used an adaptive sailing vessel, the Martin 16, as an platform for autonomous sailboat research. The project involved installing necessary sensors, designing the electrical system, and developing control strategies for the sail and rudder.
- Installed sensors and electronics on the Martin 16 sailboat
- Designed waterproof enclosures for the electronic components
- Designed and implemented control algorithms for the sail
- Tested and tuned the system for autonomous sailing
Communication Organization Outreach
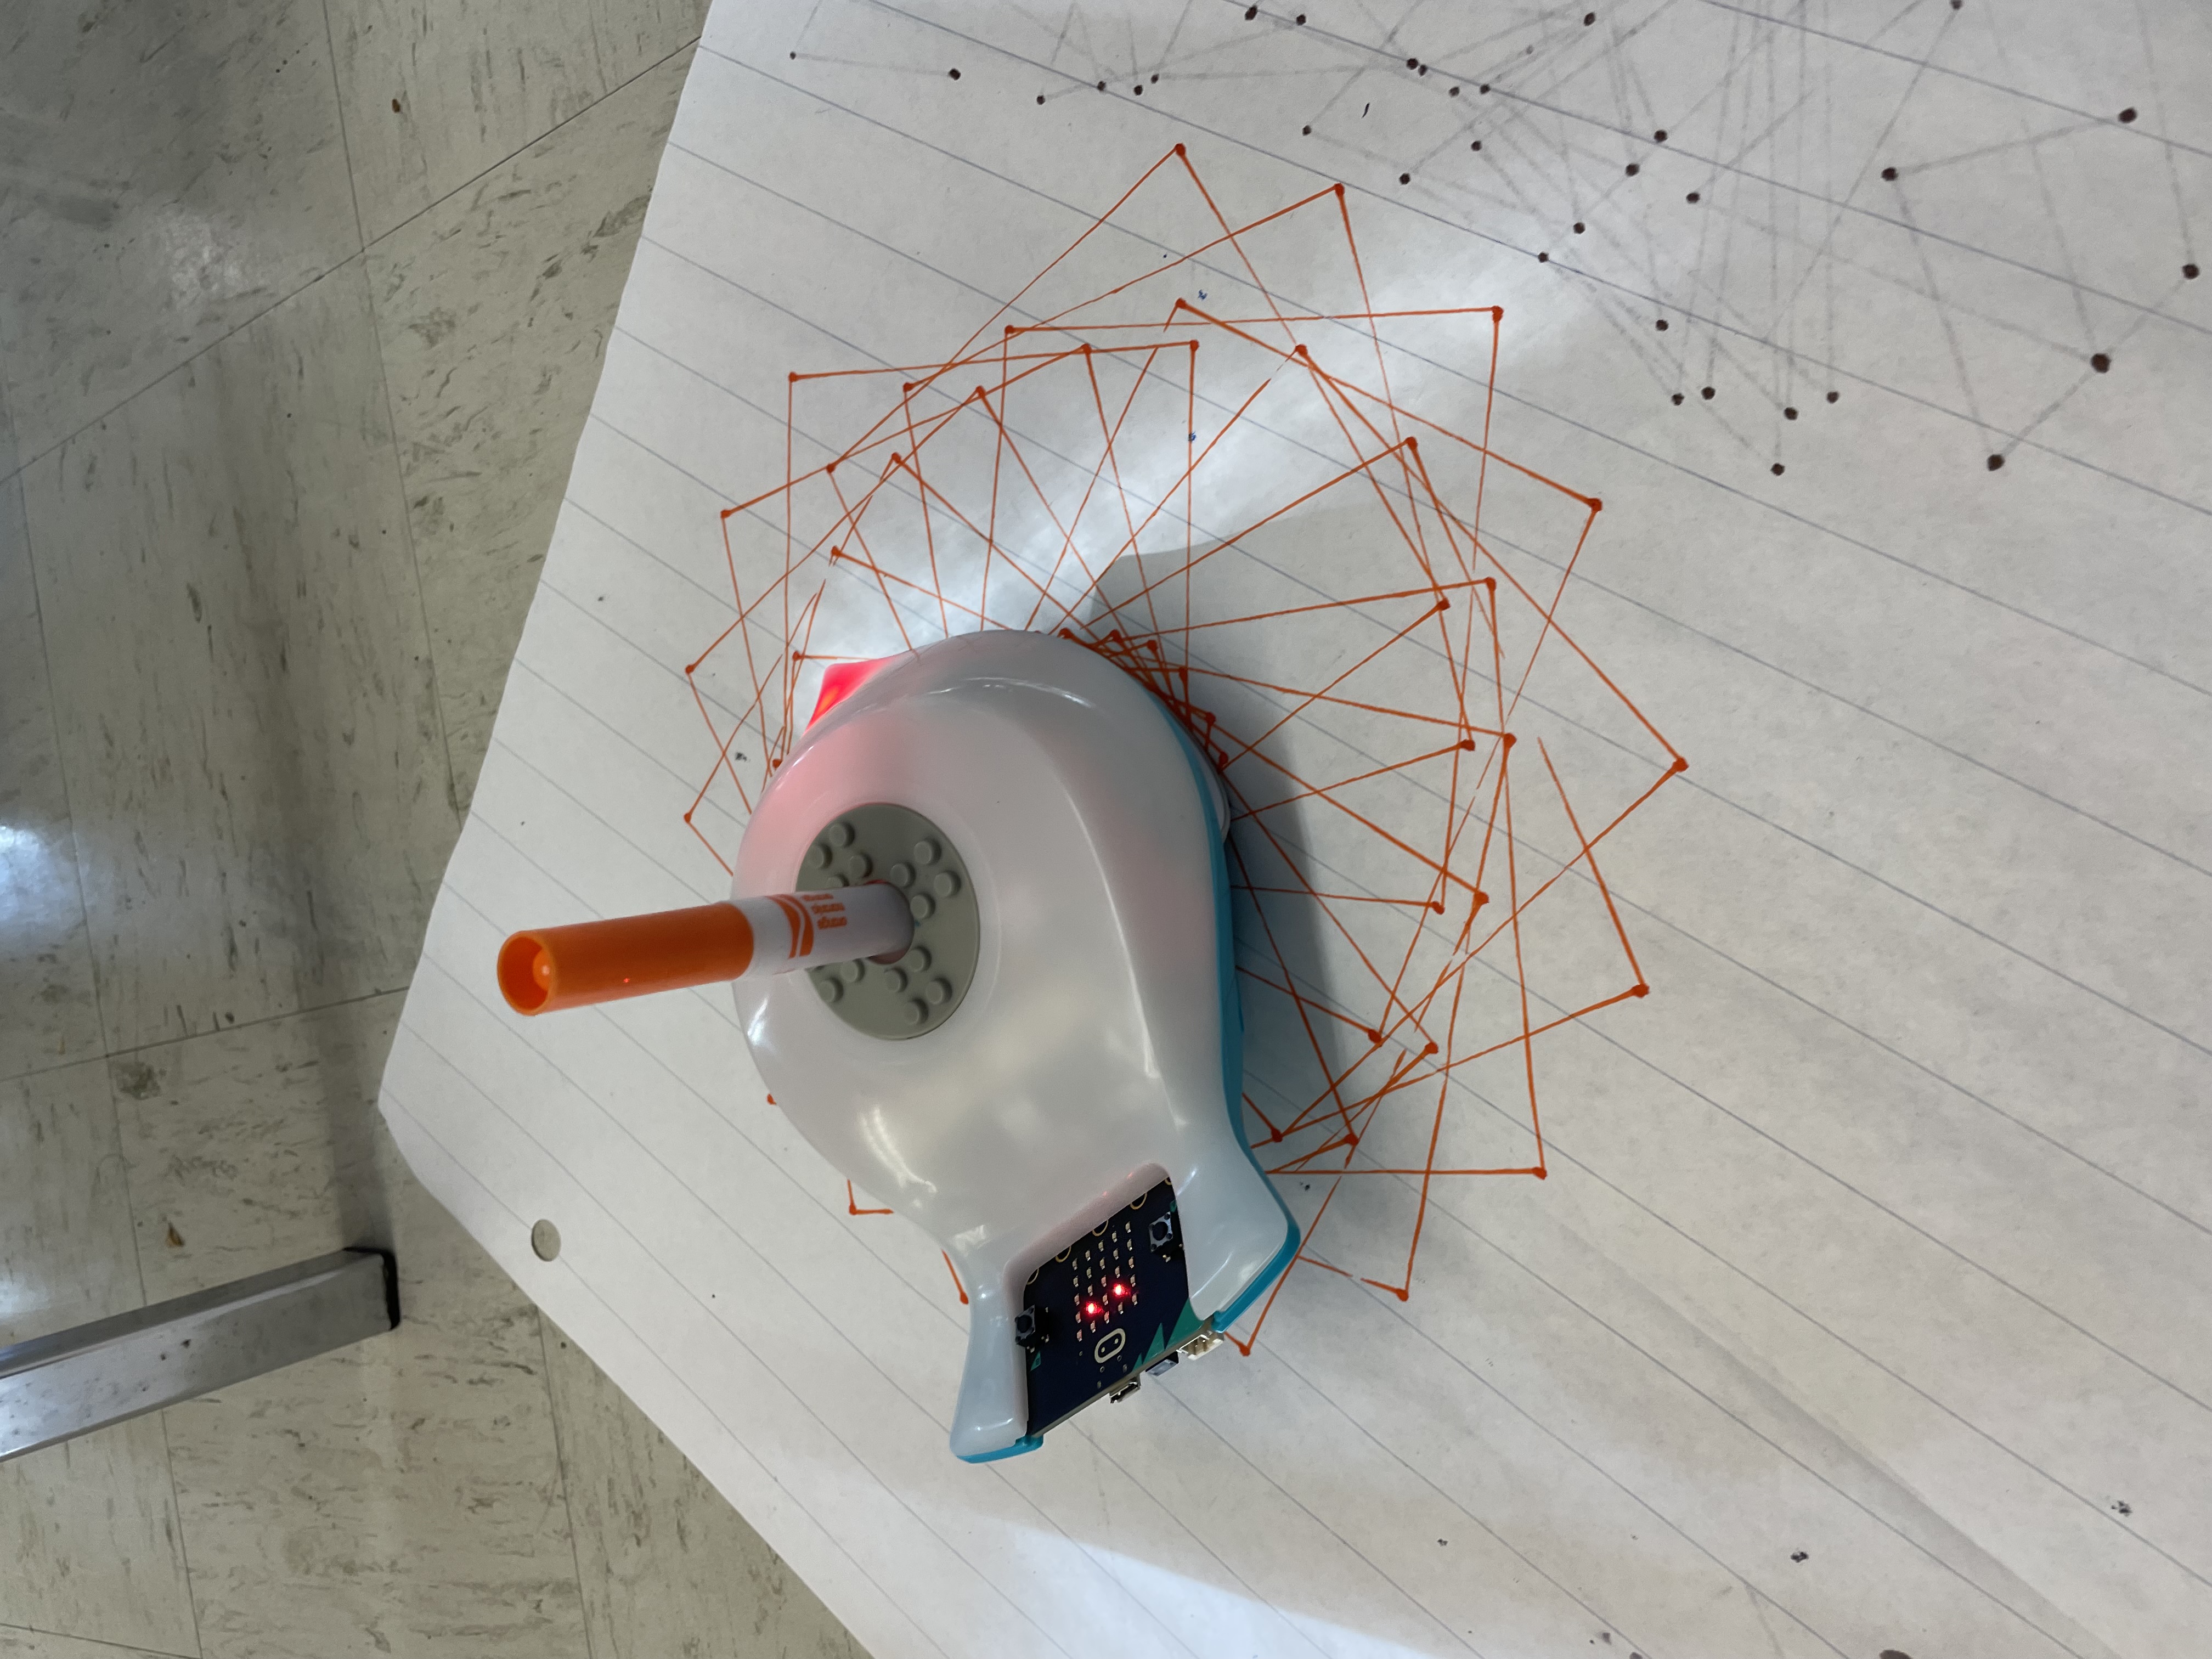
Mobile Finch Robots Robogal's Workshop
Designed curriculum for robotics workshops for grades 1-8 using Finch robots. The workshops focused on teaching students about robotics, programming, and problem-solving through hands-on activities.
- Chose important age-appropriate concepts to include
- Developed interactive activities for student engagement
- Taught others how to deliver the workshops effectively
Arduino Hardware Interface
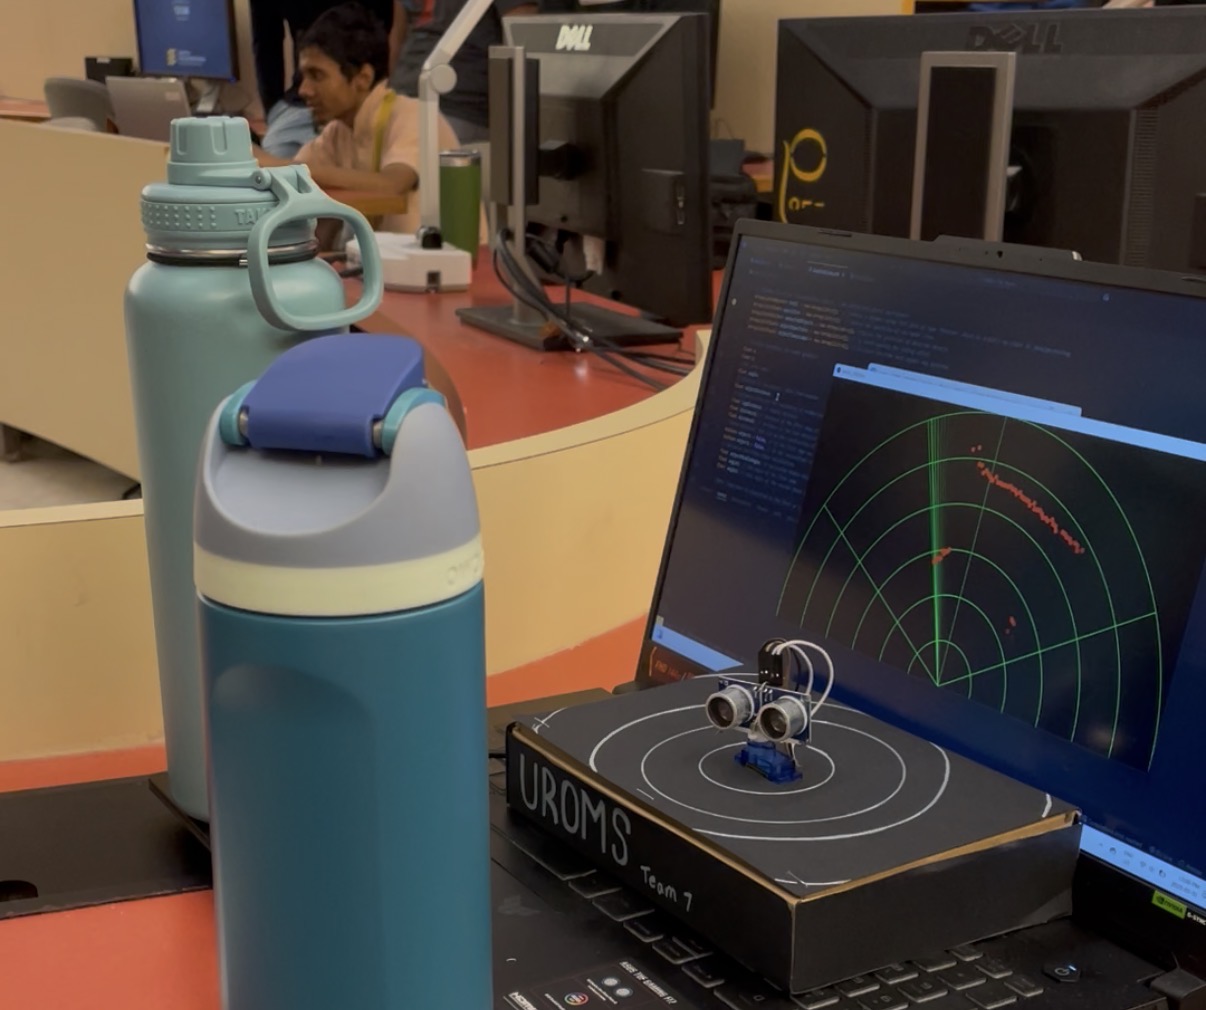
Ultrasonic Radar Object Mapping System
Designed a system to map objects in a room using an ultrasonic sensor mounted on a servo motor. The system collected distance measurements and created a 2D map of the environment.
- Programmed the servo with Arduino
- Used serial messages to commmunicate with the interface
- Implemented a queue as a buffer loop
Field Testing Research
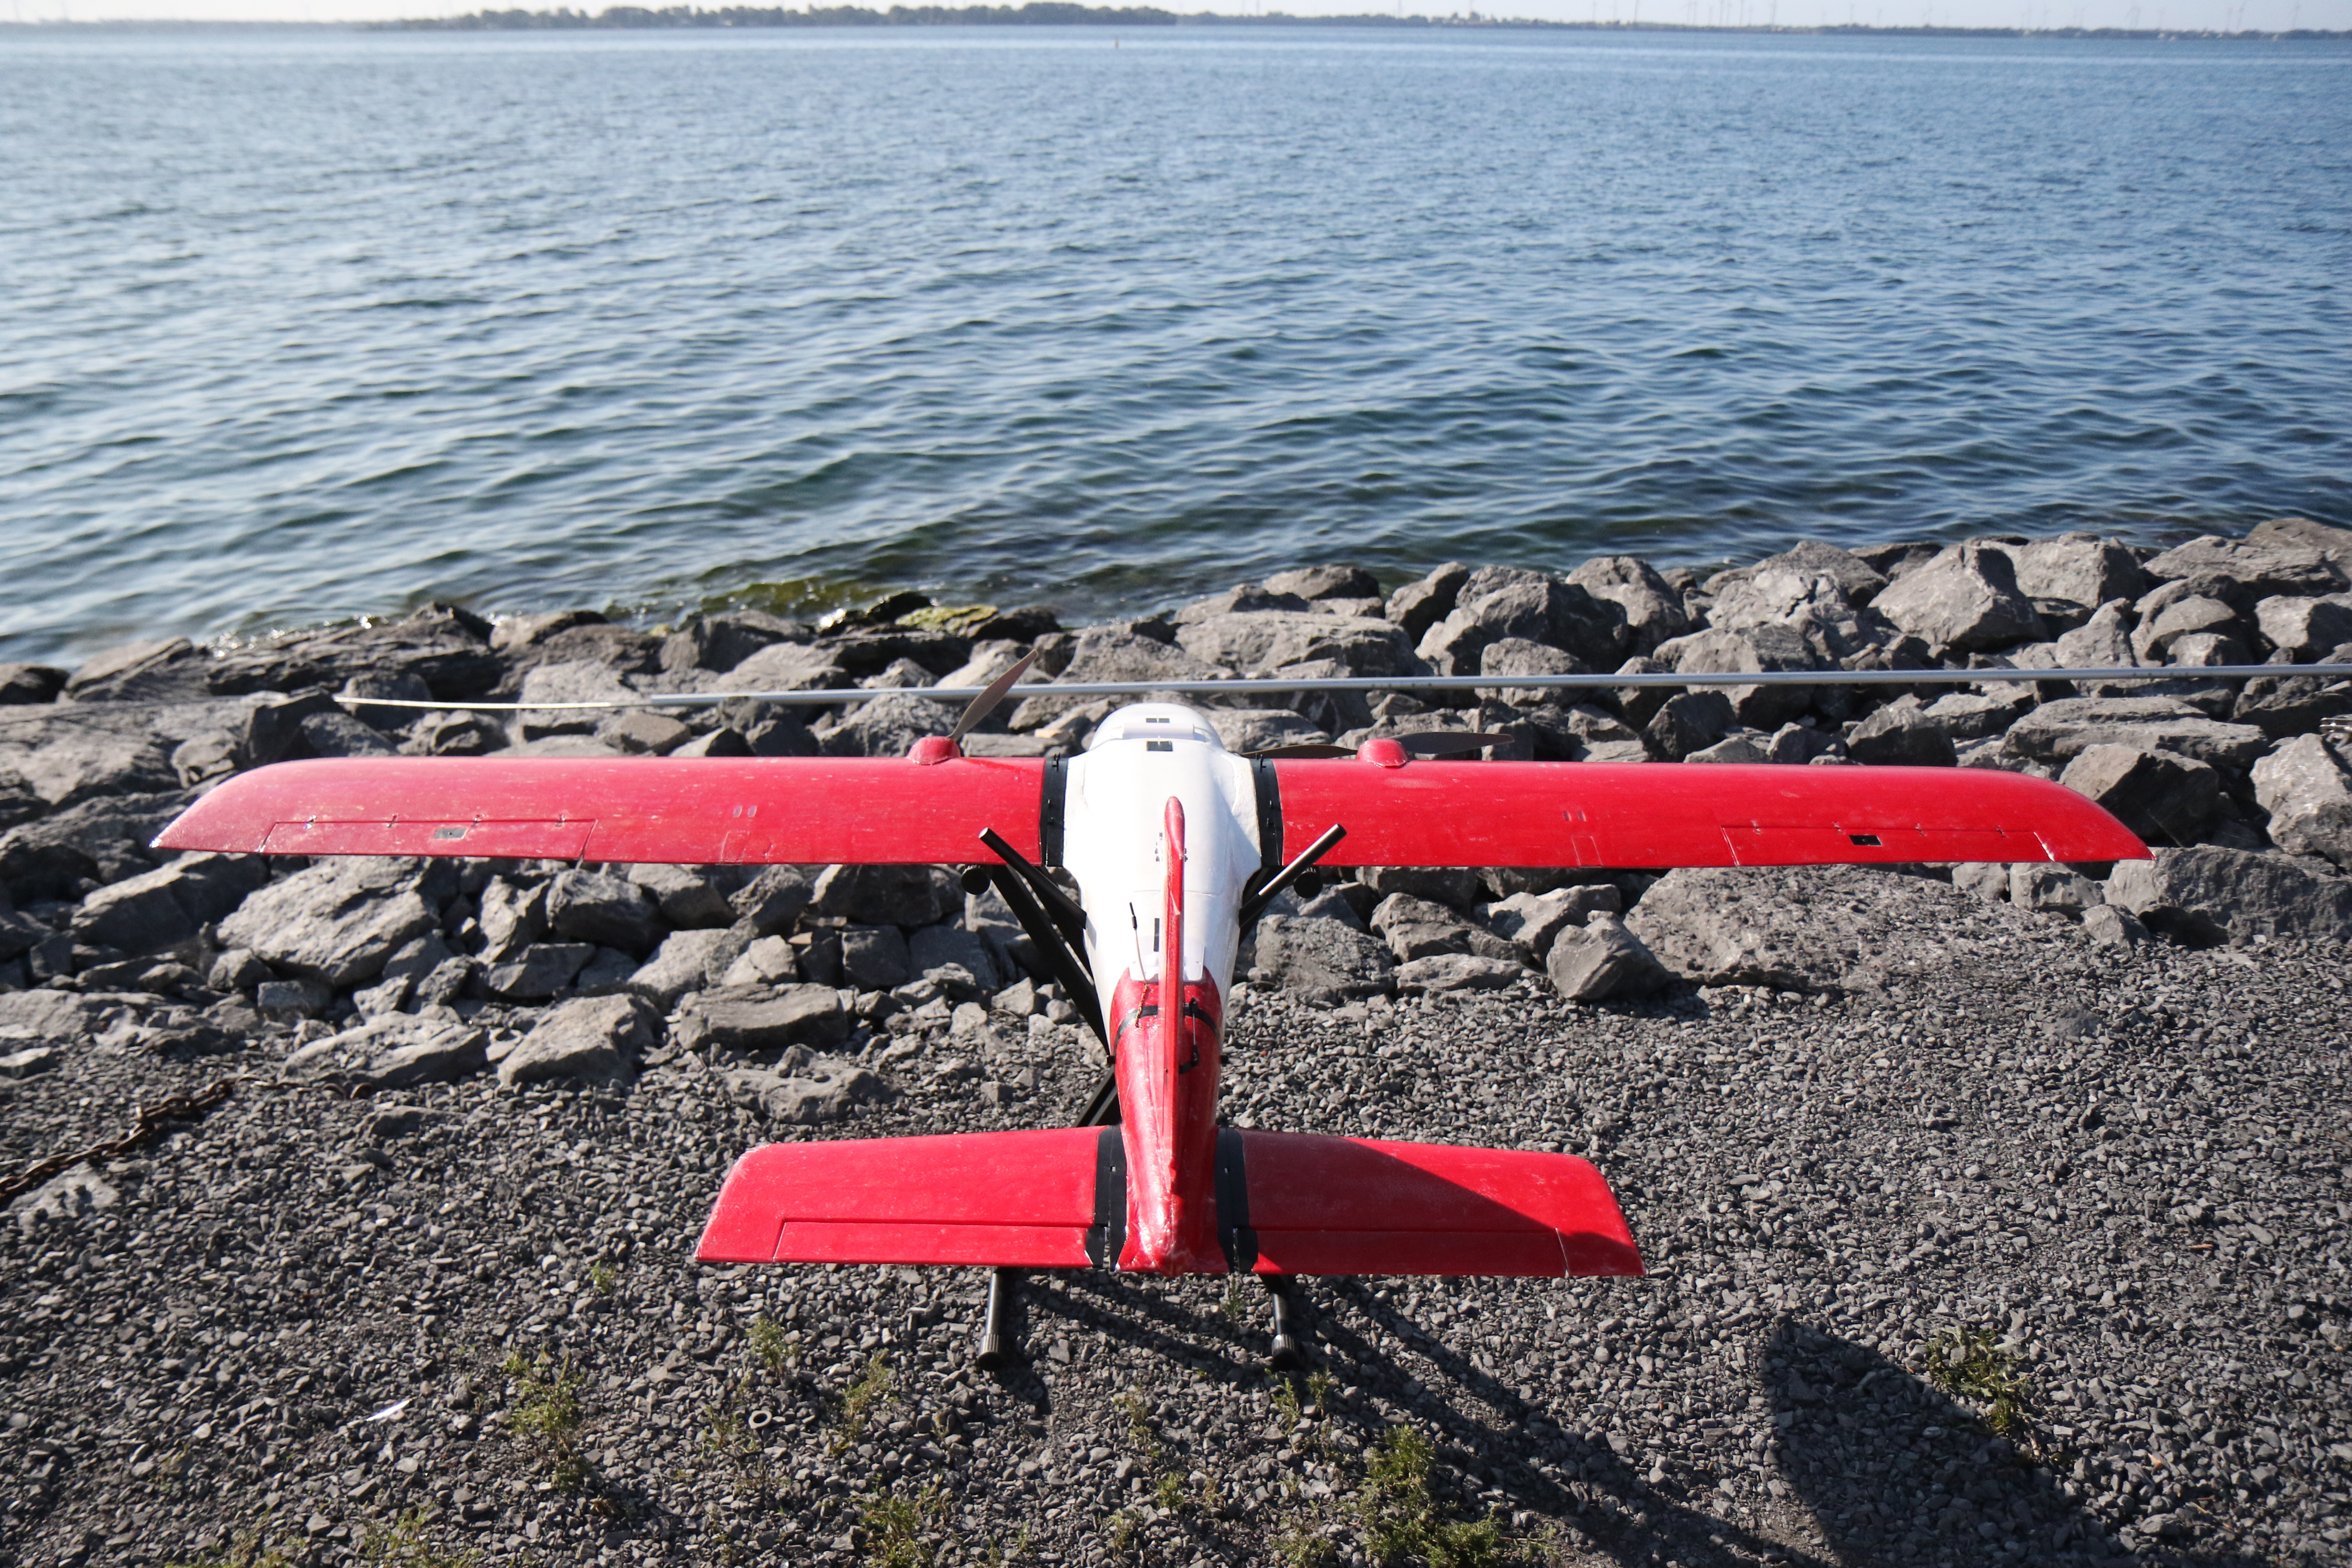
Marine Search and Rescue Research Testing
Assisting in research testing for a marine search and rescue project. Using a custom fixed wing drone, the team tested detection and tracking of objects and people in the water.
- Facilitated testing with drone retrieval
- Designed waterproof electrical solutions
Control Navigation Programming
Autonomous Delivery Robot
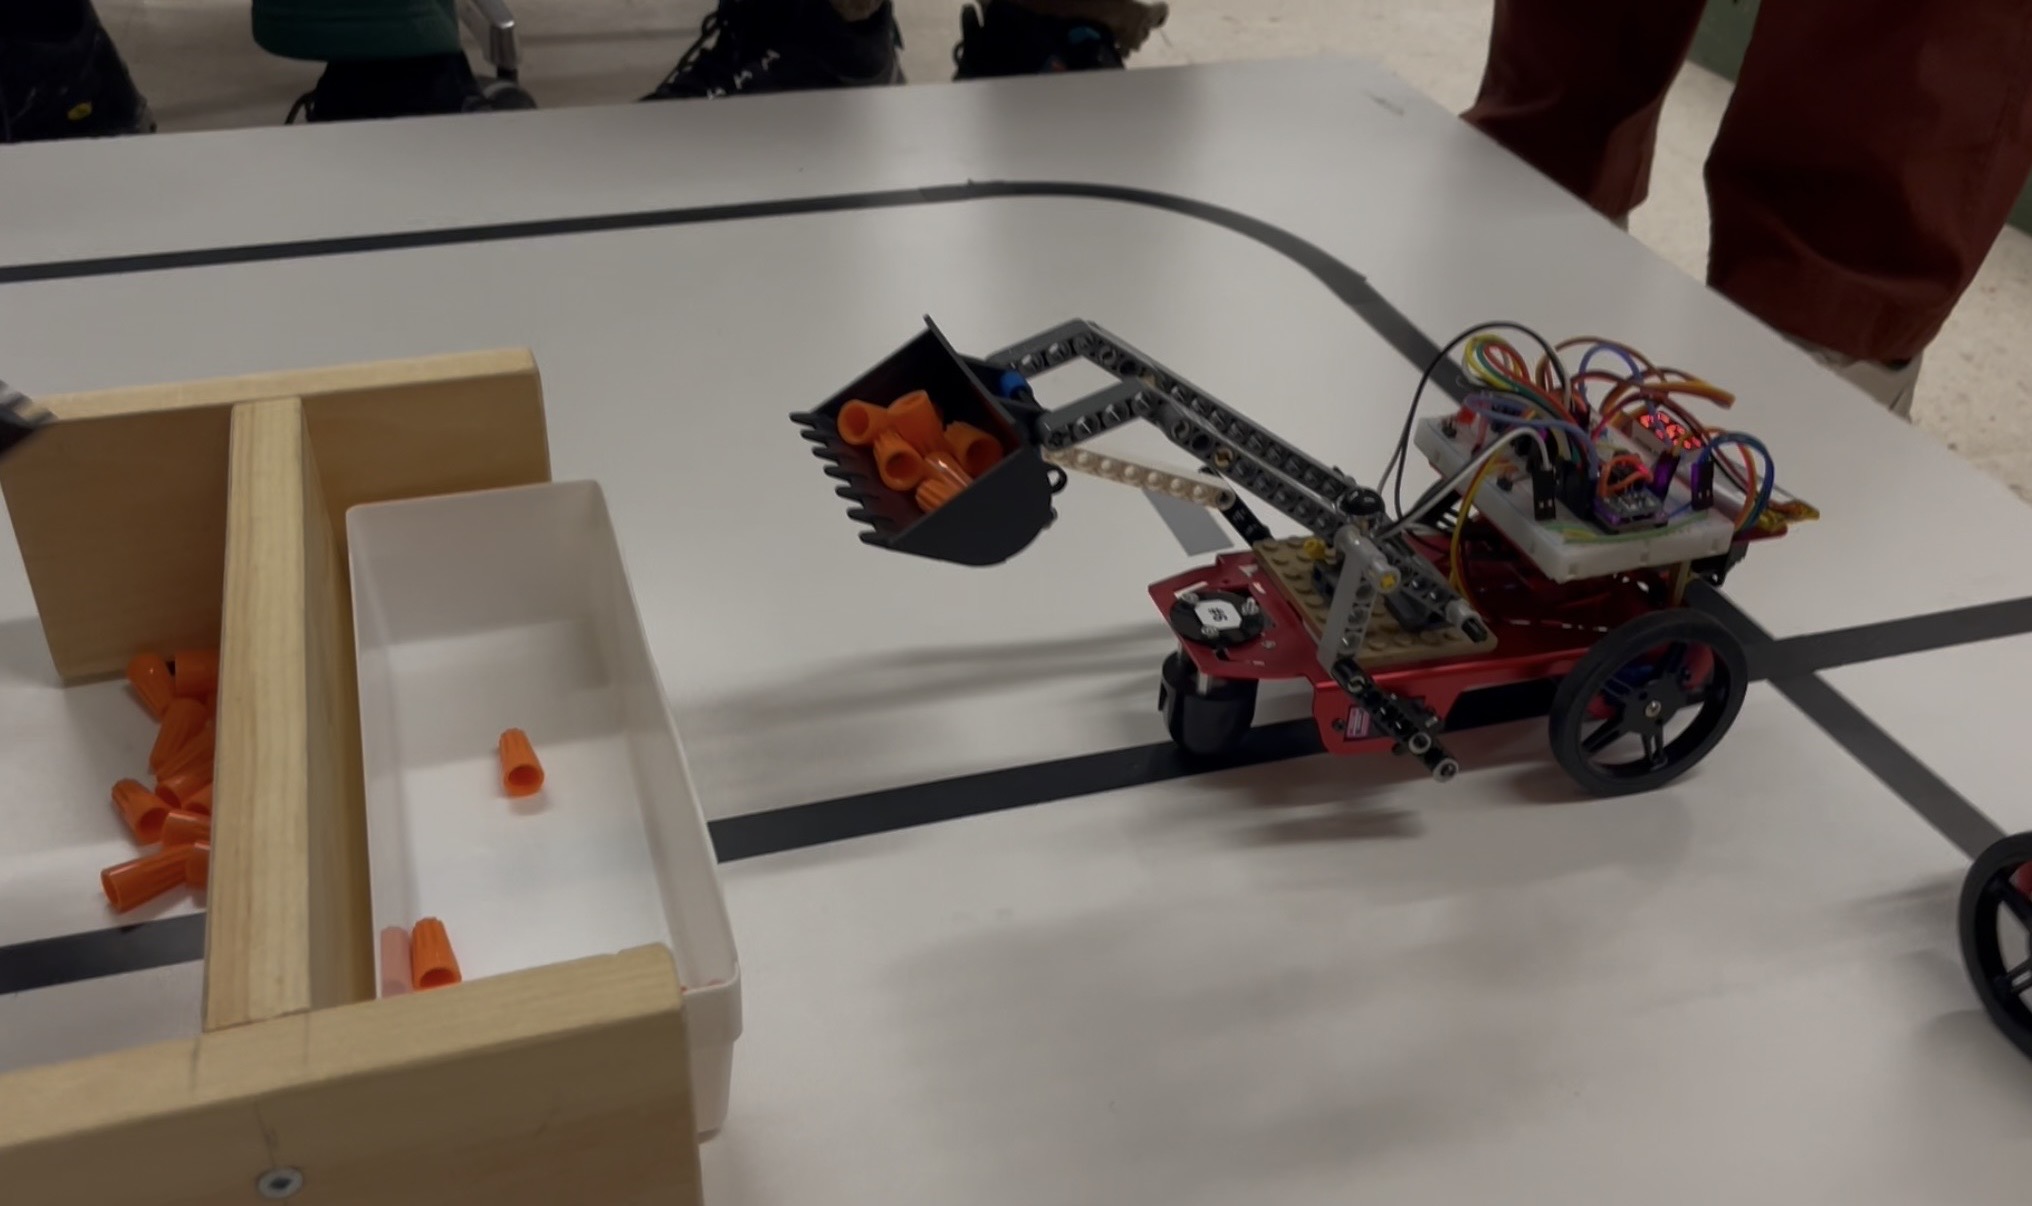
Designed an autonomous delivery robot using a IstyBitsy and various sensors. The robot was able to navigate through a predefined path and deliver parts to designated locations.
- Programmed the robot with C++ and an ItsyBitsy Microcontroller
- Implemented and calibrater a laser distance sensor for obstacle derection
- Used a line sensor for path following